Research
Robot Control
Control of a robotic swarm
 Fig. Navigation control of a robotic swarm.
The leader robot is remotely controlled, and each other robot in the swarm follows its own target robot, which allows the swarm to navigate.
 Fig. Cooperative transportation of an object by a robotic swarm.
Multiple robots cooperating enable the transformation of objects that cannot be transported by a single robot only.
- A robotic swarm is composed of multiple robots and can cope with certain tasks that a single robot cannot handle. The robotic swarms are expected to be applicable to main tasks such as cooperative coverage, surveillance, and transportation.
- We have proposed control methods for robotic swarms, such as navigating the swarm to a destination and cooperatively transporting an object. Additionally, we have successfully mathematically proven the maintenance of the swarm's connectivity, stability, and feasibility of task execution.
- In particular, to prevent system breakdown even with an increasing number of robots, each robot in the swarm is controlled using locally available information. Distributed control, which achieves the system's global functions through local information, is the essence of swarm control.
Navigation Control for Robotic Swarms Under Robot Failure
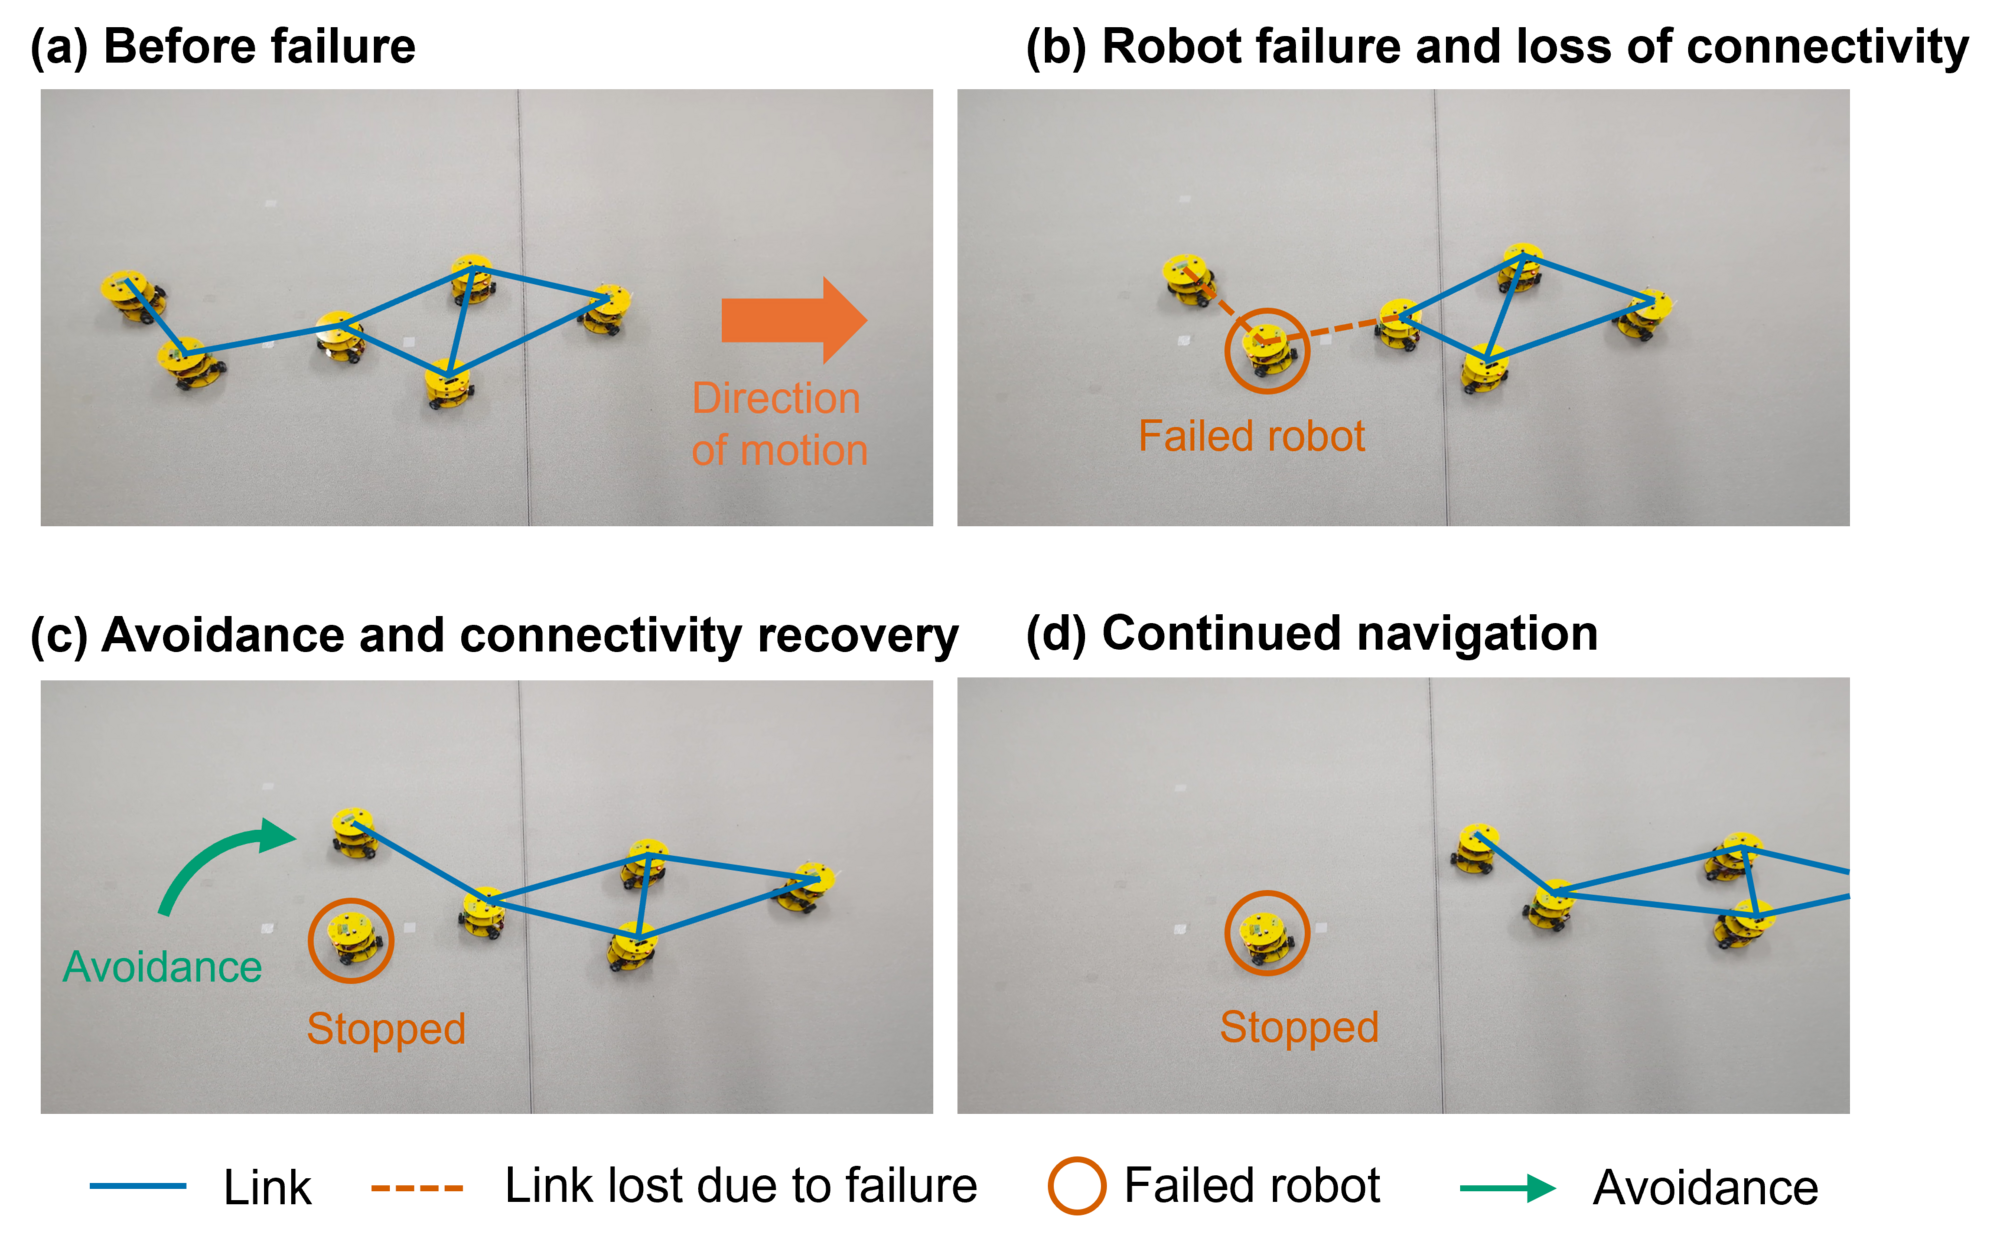 Fig. Experimental demonstration of swarm connectivity recovery while avoiding a failed robot.
(a) Six robots move while maintaining connectivity. (b) One robot fails and stops, causing the swarm to lose connectivity. (c) The remaining robots avoid the failed robot and restore connectivity. (d) Navigation resumes.
- When multiple robots move cooperatively, a robot that fails and stops can obstruct other robots and disrupt swarm connectivity. Our laboratory develops control methods that enable the remaining robots to avoid the stopped robot, restore connectivity, and continue following the leader.
- In the proposed method, each robot determines its motion based on the positions and movements of nearby robots. When a robot fails, its neighbors use its direction of motion immediately before the failure as a guide to move around it and, when necessary, wait until connectivity is restored. These behaviors are incorporated into a model predictive control framework, which predicts future motion to determine each robot’s velocity while accounting for limits on sensing range and speed.
Related Publications
- T. Endo, Y. Fukao, Y. Kamihoriuchi, and P. T. Hieu, “Distributed MPC-Based Navigation for Robotic Swarm Systems Under Robot Failure,” IEEE Transactions on Automation Science and Engineering, 23, pp. 17906-17921, 2026.
- R. Maeda, T. Endo, and F. Matsuno, “Decentralized Navigation Method for Swarm Robots with Individual Loss Due to Failure”, Journal of the Franklin Institute, 360(11), pp. 7148-7179, 2023.
- K. Yamaguchi, T. Endo, and F. Matsuno, “Formation Control of Multi-Agent System Based on Higher-Order Partial Differential Equations”, IEEE Trans. on Control Systems Technology, 30(2), pp.570-582, 2022.
- R. Koike, T. Endo, and F. Matsuno, “Output-based dynamic event-triggered consensus control for linear multiagent systems”, Automatica, 133, Article 109863, 2021.
- R. Maeda, T. Endo, and F. Matsuno, “Decentralized Navigation for Heterogeneous Swarm Robots with Limited Field of View”, IEEE Robotics and Automation Letters (RA-L), 2(2), pp.904-911, 2017.